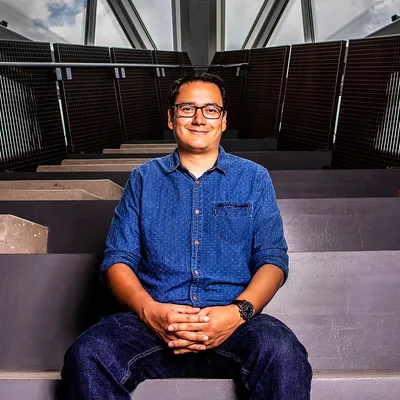
David Saldaña leads SwarmsLab in the Department of Computer Science and Engineering at Lehigh University. His research focuses on flying modular robots, cooperative multi-robot systems, and resilient robot swarms.
Before joining Lehigh, he worked as a postdoctoral researcher in the GRASP Laboratory at the University of Pennsylvania with Prof. Vijay Kumar. He completed his PhD at the Federal University of Minas Gerais, Brazil, advised by Prof. Mario Fernando Campos and Prof. Renato Assunção in the Laboratory of Computer Vision and Robotics (VeRLab).
Education and experience
- 2025–present: Associate Professor, Computer Science & Engineering, Lehigh University.
- 2019–2025: Assistant Professor, Computer Science & Engineering, Lehigh University.
- 2026–present: Courtesy appointment, Mechanical Engineering & Mechanics, Lehigh University.
- 2017–2019: Postdoctoral researcher, GRASP Laboratory, University of Pennsylvania.
- 2015–2017: Visiting research scholar, GRASP Laboratory, University of Pennsylvania.
- 2013–2017: PhD in Computer Science, Federal University of Minas Gerais, Brazil.
- 2011–2012: MSc in Engineering — Systems Engineering, Universidad Nacional de Colombia, Medellín.
- 2005–2010: BSc in Engineering of Systems and Informatics, Universidad Nacional de Colombia, Medellín.
Office
Office 319, Building C, Mountaintop Campus, Lehigh University.
Selected publications
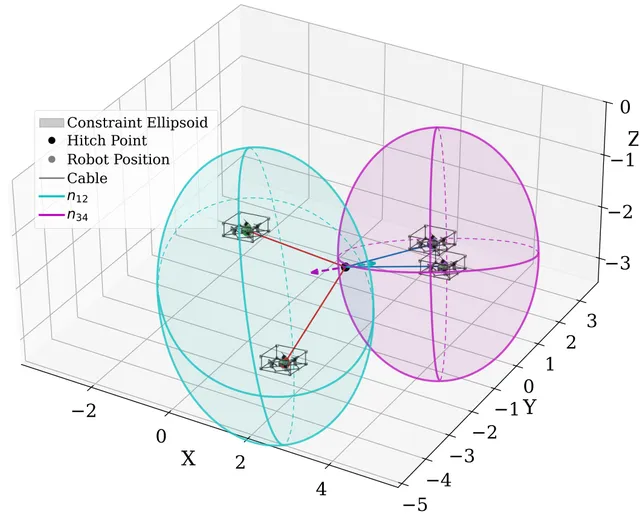 2026Conference paper
From Ellipsoids to Midair Control of Dynamic Hitches
Jiawei Xu, Subhrajit Bhattacharya, David Saldaña
2026 American Control Conference (ACC)
BibTeX
@inproceedings{xu2026ellipsoids, title={From Ellipsoids to Midair Control of Dynamic Hitches}, author={Xu, Jiawei and Bhattacharya, Subhrajit and Saldaña, David}, booktitle={2026 American Control Conference (ACC)}, year={2026}, url={https://arxiv.org/abs/2602.08116} }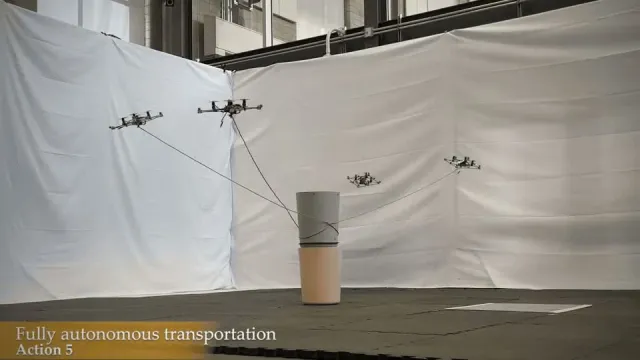 2026Journal article
From Hitch to Lift: Autonomous Cable Interlacing by Multi-UAV Teams for Aerial Grasping and Transportation
Diego S. D'Antonio, Tongshu Wu, Subhrajit Bhattacharya, David Saldaña
IEEE Transactions on Robotics
BibTeX
@article{2026-from-hitch-to-lift-autonomous-cable-interlacing-by-multi-uav-teams-for-aerial-grasping-and-transportation, title = {From Hitch to Lift: Autonomous Cable Interlacing by Multi-UAV Teams for Aerial Grasping and Transportation}, author = {Diego S. D'Antonio and Tongshu Wu and Subhrajit Bhattacharya and David Saldaña}, year = {2026}, journal = {IEEE Transactions on Robotics}, doi = {10.1109/tro.2026.3677011} }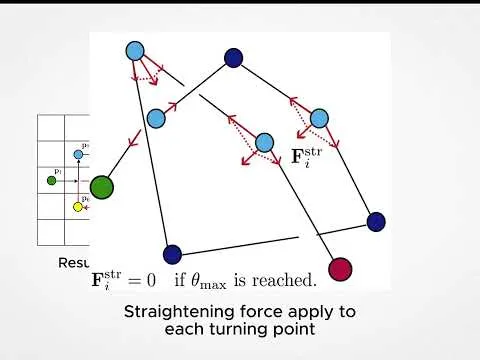 2026Conference paper
Tying Knots in the Air: Reducing the Number of Quadrotors for Aerial Knot Formation
Tongshu Wu, Edward Lopez, Diego S. D'Antonio, David Saldaña
2026 IEEE International Conference on Robotics and Automation (ICRA)
BibTeX
@inproceedings{wu2026tying, title={Tying Knots in the Air: Reducing the Number of Quadrotors for Aerial Knot Formation}, author={Wu, Tongshu and Lopez, Edward and D'Antonio, Diego S. and Saldaña, David}, booktitle={2026 IEEE International Conference on Robotics and Automation (ICRA)}, year={2026}, pages={9871--9878}, doi={10.1109/ICRA57385.2026.11697504} }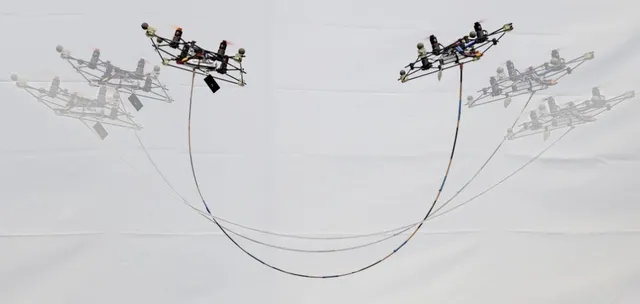 2025Journal article
AirBender: Adaptive Transportation of Bendable Objects Using Dual UAVs
Jiawei Xu, Longsen Gao, Rafael Fierro, David Saldaña
IEEE Robotics and Automation Letters
BibTeX
@article{2025-airbender-adaptive-transportation-of-bendable-objects-using-dual-uavs, title = {AirBender: Adaptive Transportation of Bendable Objects Using Dual UAVs}, author = {Jiawei Xu and Longsen Gao and Rafael Fierro and David Saldaña}, year = {2025}, journal = {IEEE Robotics and Automation Letters}, pages = {2790-2797}, volume = {10}, number = {3}, doi = {10.1109/lra.2025.3536276}, url = {https://doi.org/10.1109/lra.2025.3536276} }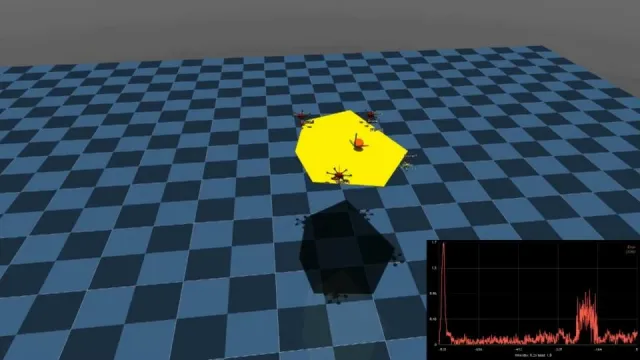 2025Book chapter
Decentralized Adaptive Aerospace Transportation of Unknown Loads Using A Team of Robots
Longsen Gao, Kevin Aubert, David Saldaña, Claus Danielson, Rafael Fierro
Distributed Autonomous Robotic Systems: 17th International Symposium
Presented at DARS 2024; chapter published online in 2025.
BibTeX
@incollection{2025-decentralized-adaptive-aerospace-transportation-of-unknown-loads-using-a-team-of-robots, title = {Decentralized Adaptive Aerospace Transportation of Unknown Loads Using A Team of Robots}, author = {Longsen Gao and Kevin Aubert and David Saldaña and Claus Danielson and Rafael Fierro}, year = {2025}, booktitle = {Distributed Autonomous Robotic Systems: 17th International Symposium}, pages = {28–41}, volume = {34}, doi = {10.1007/978-3-032-04584-3_3}, url = {https://doi.org/10.1007/978-3-032-04584-3_3} }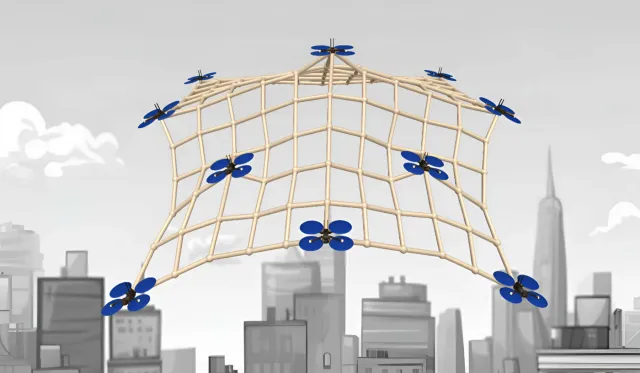 2025Conference paper
FlySurf: A Flying Robotic Surface with Shape Morphing Control
Kevin Aubert, David Saldaña, Rafael Fierro
2025 American Control Conference (ACC)
BibTeX
@inproceedings{2025-flysurf-a-flying-robotic-surface-with-shape-morphing-control, title = {FlySurf: A Flying Robotic Surface with Shape Morphing Control}, author = {Kevin Aubert and David Saldaña and Rafael Fierro}, year = {2025}, booktitle = {2025 American Control Conference (ACC)}, doi = {10.23919/acc63710.2025.11107545} }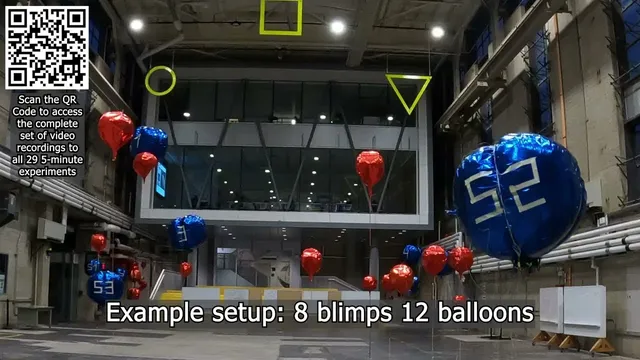 2025Conference paper
MochiSwarm: A testbed for robotic blimps in realistic environments
Jiawei Xu, Thong Vu, Diego S. D’Antonio, David Saldaña
IEEE International Conference on Robotics and Automation (ICRA)
BibTeX
@inproceedings{2025-mochiswarm, title = {MochiSwarm: A testbed for robotic blimps in realistic environments}, author = {Jiawei Xu and Thong Vu and Diego S. D’Antonio and David Saldaña}, year = {2025}, booktitle = {IEEE International Conference on Robotics and Automation (ICRA)}, url = {https://arxiv.org/abs/2503.03077} }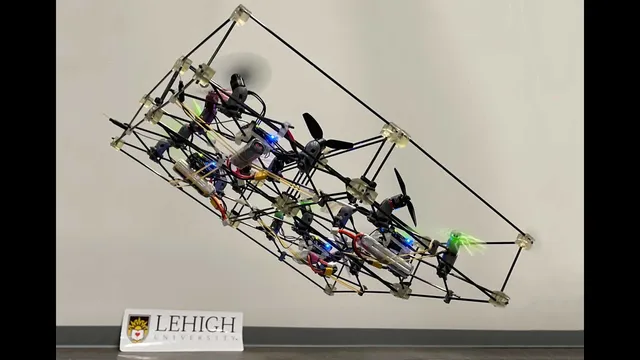 2025Journal article
Modular Multirotors: From Quadrotors to Fully-Actuated Aerial Vehicles
Jiawei Xu, Diego S. D'Antonio, David Saldaña
IEEE Transactions on Automation Science and Engineering
BibTeX
@article{2025-modular-multirotors-from-quadrotors-to-fully-actuated-aerial-vehicles, title = {Modular Multirotors: From Quadrotors to Fully-Actuated Aerial Vehicles}, author = {Jiawei Xu and Diego S. D'Antonio and David Saldaña}, year = {2025}, journal = {IEEE Transactions on Automation Science and Engineering}, pages = {19328-19339}, volume = {22}, doi = {10.1109/tase.2025.3594579}, url = {https://doi.org/10.1109/tase.2025.3594579} }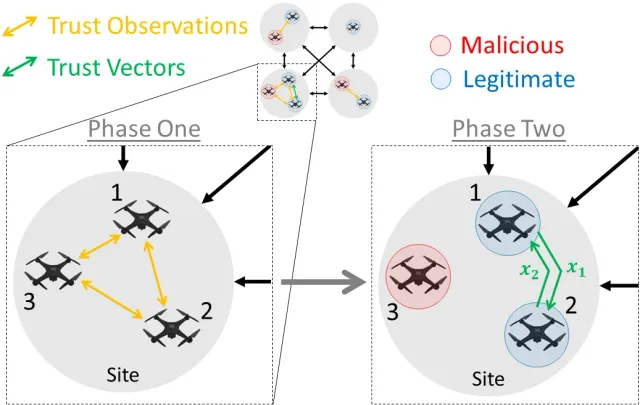 2025Journal article
quasi-Dynamic Crowd Vetting: Collaborative Detection of Malicious Robots in Dynamic Communication Networks
Matthew Cavorsi, Frederik Mallmann-Trenn, David Saldaña, Stephanie Gil
IEEE Transactions on Robotics
BibTeX
@article{2025-quasi-dynamic-crowd-vetting-collaborative-detection-of-malicious-robots-in-dynamic-communication-networks, title = {quasi-Dynamic Crowd Vetting: Collaborative Detection of Malicious Robots in Dynamic Communication Networks}, author = {Matthew Cavorsi and Frederik Mallmann-Trenn and David Saldaña and Stephanie Gil}, year = {2025}, journal = {IEEE Transactions on Robotics}, pages = {5533-5549}, volume = {41}, doi = {10.1109/tro.2025.3608702}, url = {https://doi.org/10.1109/tro.2025.3608702} }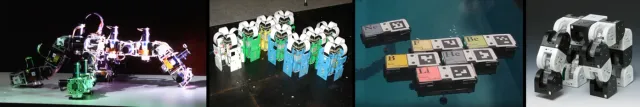 2025Book chapter
Reconfigurable Systems
David Saldaña, Gedaliah Knizhnik, Bruno Gabrich, Mark Yim
Encyclopedia of Robotics
BibTeX
@incollection{2025-reconfigurable-systems, title = {Reconfigurable Systems}, author = {David Saldaña and Gedaliah Knizhnik and Bruno Gabrich and Mark Yim}, year = {2025}, booktitle = {Encyclopedia of Robotics}, url = {https://scholar.google.com/citations?view_op=view_citation&hl=en&user=VU1s_Z8AAAAJ&citation_for_view=VU1s_Z8AAAAJ:sNmaIFBj_lkC} }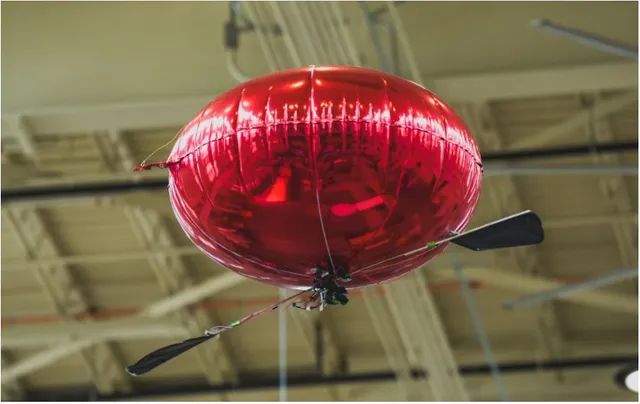 2025Conference paper
The Spinning Blimp: Design and Control of a Novel Minimalist Aerial Vehicle Leveraging Rotational Dynamics and Locomotion
Leonardo Santens, Diego S. D’Antonio, Shuhang Hou, David Saldaña
IEEE International Conference on Robotics and Automation (ICRA)
BibTeX
@inproceedings{2025-spinning-blimp, title = {The Spinning Blimp: Design and Control of a Novel Minimalist Aerial Vehicle Leveraging Rotational Dynamics and Locomotion}, author = {Leonardo Santens and Diego S. D’Antonio and Shuhang Hou and David Saldaña}, year = {2025}, booktitle = {IEEE International Conference on Robotics and Automation (ICRA)}, url = {https://arxiv.org/abs/2503.04112} }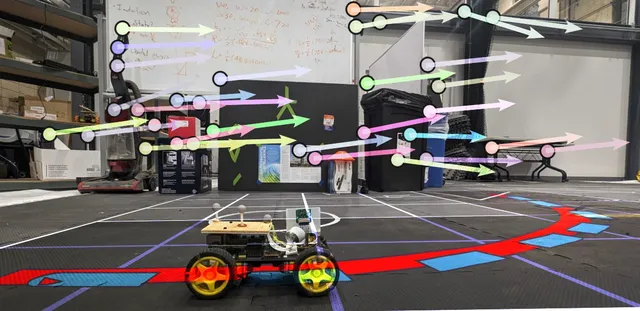 2024Conference paper
KT-Imitation: Efficient Visual Imitation for Autonomous Navigation Based on Keypoint Timeline
Karen Li, Hanqing Qi, Jiawei Xu, Edward Jeffs, David Saldaña
2024 Latin American Robotics Symposium (LARS)
BibTeX
@inproceedings{2024-kt-imitation-efficient-visual-imitation-for-autonomous-navigation-based-on-keypoint-timeline, title = {KT-Imitation: Efficient Visual Imitation for Autonomous Navigation Based on Keypoint Timeline}, author = {Karen Li and Hanqing Qi and Jiawei Xu and Edward Jeffs and David Saldaña}, year = {2024}, booktitle = {2024 Latin American Robotics Symposium (LARS)}, doi = {10.1109/lars64411.2024.10786409} }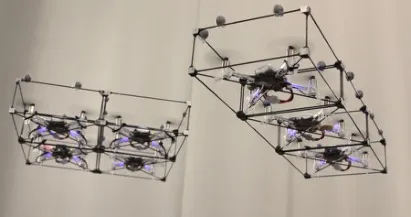 2024Conference paper
Rotor Fault Detection and Isolation in Aerial Vehicles with Dozens of Rotors
Neeraj Gandhi, Jiawei Xu, David Saldaña, Linh Thi Xuan Phan
2024 Latin American Robotics Symposium (LARS)
BibTeX
@inproceedings{2024-rotor-fault-detection-and-isolation-in-aerial-vehicles-with-dozens-of-rotors, title = {Rotor Fault Detection and Isolation in Aerial Vehicles with Dozens of Rotors}, author = {Neeraj Gandhi and Jiawei Xu and David Saldaña and Linh Thi Xuan Phan}, year = {2024}, booktitle = {2024 Latin American Robotics Symposium (LARS)}, doi = {10.1109/lars64411.2024.10786448} } 2023Conference paper
A Novel Low-Cost, Recyclable, Easy-to-Build Robot Blimp For Transporting Supplies in Hard-to-Reach Locations
Karen Li, Shuhang Hou, Matyas Negash, Jiawei Xu, Edward Jeffs, Diego S. D'Antonio, David Saldaña
2023 IEEE Global Humanitarian Technology Conference (GHTC)
BibTeX
@inproceedings{2023-a-novel-low-cost-recyclable-easy-to-build-robot-blimp-for-transporting-supplies-in-hard-to-reach-locations, title = {A Novel Low-Cost, Recyclable, Easy-to-Build Robot Blimp For Transporting Supplies in Hard-to-Reach Locations}, author = {Karen Li and Shuhang Hou and Matyas Negash and Jiawei Xu and Edward Jeffs and Diego S. D'Antonio and David Saldaña}, year = {2023}, booktitle = {2023 IEEE Global Humanitarian Technology Conference (GHTC)}, pages = {36-42}, doi = {10.1109/ghtc56179.2023.10355047}, url = {https://doi.org/10.1109/ghtc56179.2023.10355047} }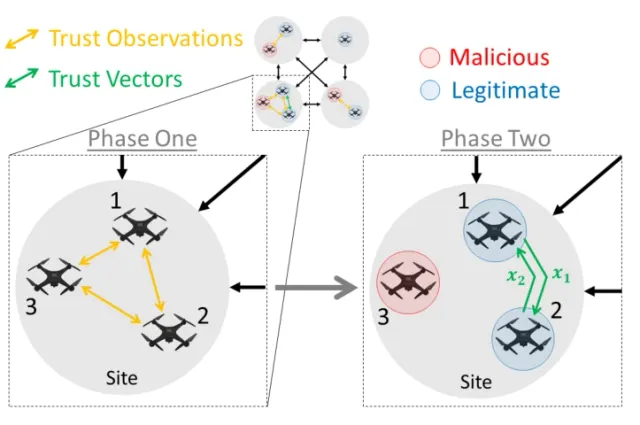 2023Conference paper
Dynamic Crowd Vetting: Collaborative Detection of Malicious Robots in Dynamic Communication Networks
Matthew Cavorsi, Frederik Mallmann-Trenn, David Saldaña, Stephanie Gil
2023 62nd IEEE Conference on Decision and Control (CDC)
BibTeX
@inproceedings{2023-dynamic-crowd-vetting-collaborative-detection-of-malicious-robots-in-dynamic-communication-networks,
  title = {Dynamic Crowd Vetting: Collaborative Detection of Malicious Robots in Dynamic Communication Networks},
  author = {Matthew Cavorsi and Frederik Mallmann-Trenn and David Saldaña and Stephanie Gil},
  year = {2023},
  booktitle = {2023 62nd IEEE Conference on Decision and Control (CDC)},
  pages = {7546-7553},
  doi = {10.1109/cdc49753.2023.10383774},
  url = {https://doi.org/10.1109/cdc49753.2023.10383774}
}