All team members
Tony Wu
Ph.D. Student
Aerial Manipulation
Selected publications
 2026Journal article
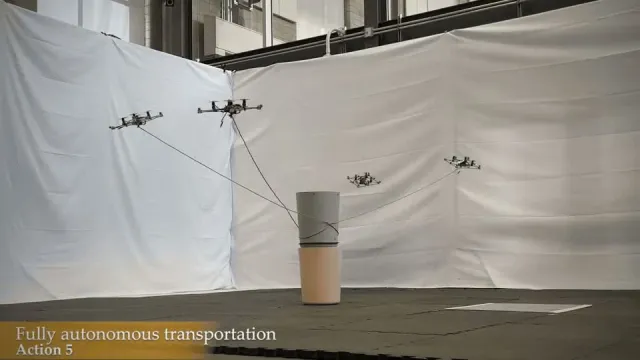
From Hitch to Lift: Autonomous Cable Interlacing by Multi-UAV Teams for Aerial Grasping and Transportation
Diego S. D'Antonio, Tongshu Wu, Subhrajit Bhattacharya, David Saldaña
IEEE Transactions on Robotics
BibTeX
@article{2026-from-hitch-to-lift-autonomous-cable-interlacing-by-multi-uav-teams-for-aerial-grasping-and-transportation, title = {From Hitch to Lift: Autonomous Cable Interlacing by Multi-UAV Teams for Aerial Grasping and Transportation}, author = {Diego S. D'Antonio and Tongshu Wu and Subhrajit Bhattacharya and David Saldaña}, year = {2026}, journal = {IEEE Transactions on Robotics}, doi = {10.1109/tro.2026.3677011} }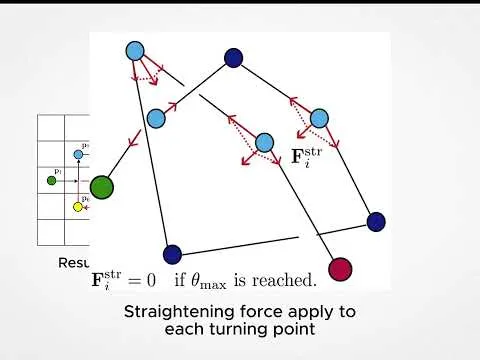 2026Conference paper
Tying Knots in the Air: Reducing the Number of Quadrotors for Aerial Knot Formation
Tongshu Wu, Edward Lopez, Diego S. D'Antonio, David Saldaña
2026 IEEE International Conference on Robotics and Automation (ICRA)
BibTeX
@inproceedings{wu2026tying,
  title={Tying Knots in the Air: Reducing the Number of Quadrotors for Aerial Knot Formation},
  author={Wu, Tongshu and Lopez, Edward and D'Antonio, Diego S. and Saldaña, David},
  booktitle={2026 IEEE International Conference on Robotics and Automation (ICRA)},
  year={2026},
  pages={9871--9878},
  doi={10.1109/ICRA57385.2026.11697504}
}