All team members
Edward Caleb Lopez
Ph.D. Student
Aerial Robotics, Bendable objects and Control
Selected publications
 2026Conference paper
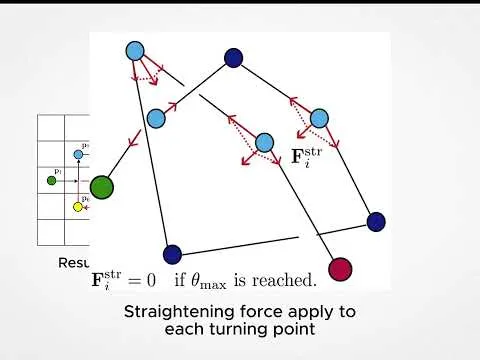
Tying Knots in the Air: Reducing the Number of Quadrotors for Aerial Knot Formation
Tongshu Wu, Edward Lopez, Diego S. D'Antonio, David Saldaña
2026 IEEE International Conference on Robotics and Automation (ICRA)
BibTeX
@inproceedings{wu2026tying,
  title={Tying Knots in the Air: Reducing the Number of Quadrotors for Aerial Knot Formation},
  author={Wu, Tongshu and Lopez, Edward and D'Antonio, Diego S. and Saldaña, David},
  booktitle={2026 IEEE International Conference on Robotics and Automation (ICRA)},
  year={2026},
  pages={9871--9878},
  doi={10.1109/ICRA57385.2026.11697504}
}