Skip to content

Lehigh University · Robotics Laboratory

We work with robots.
Lots of robots.

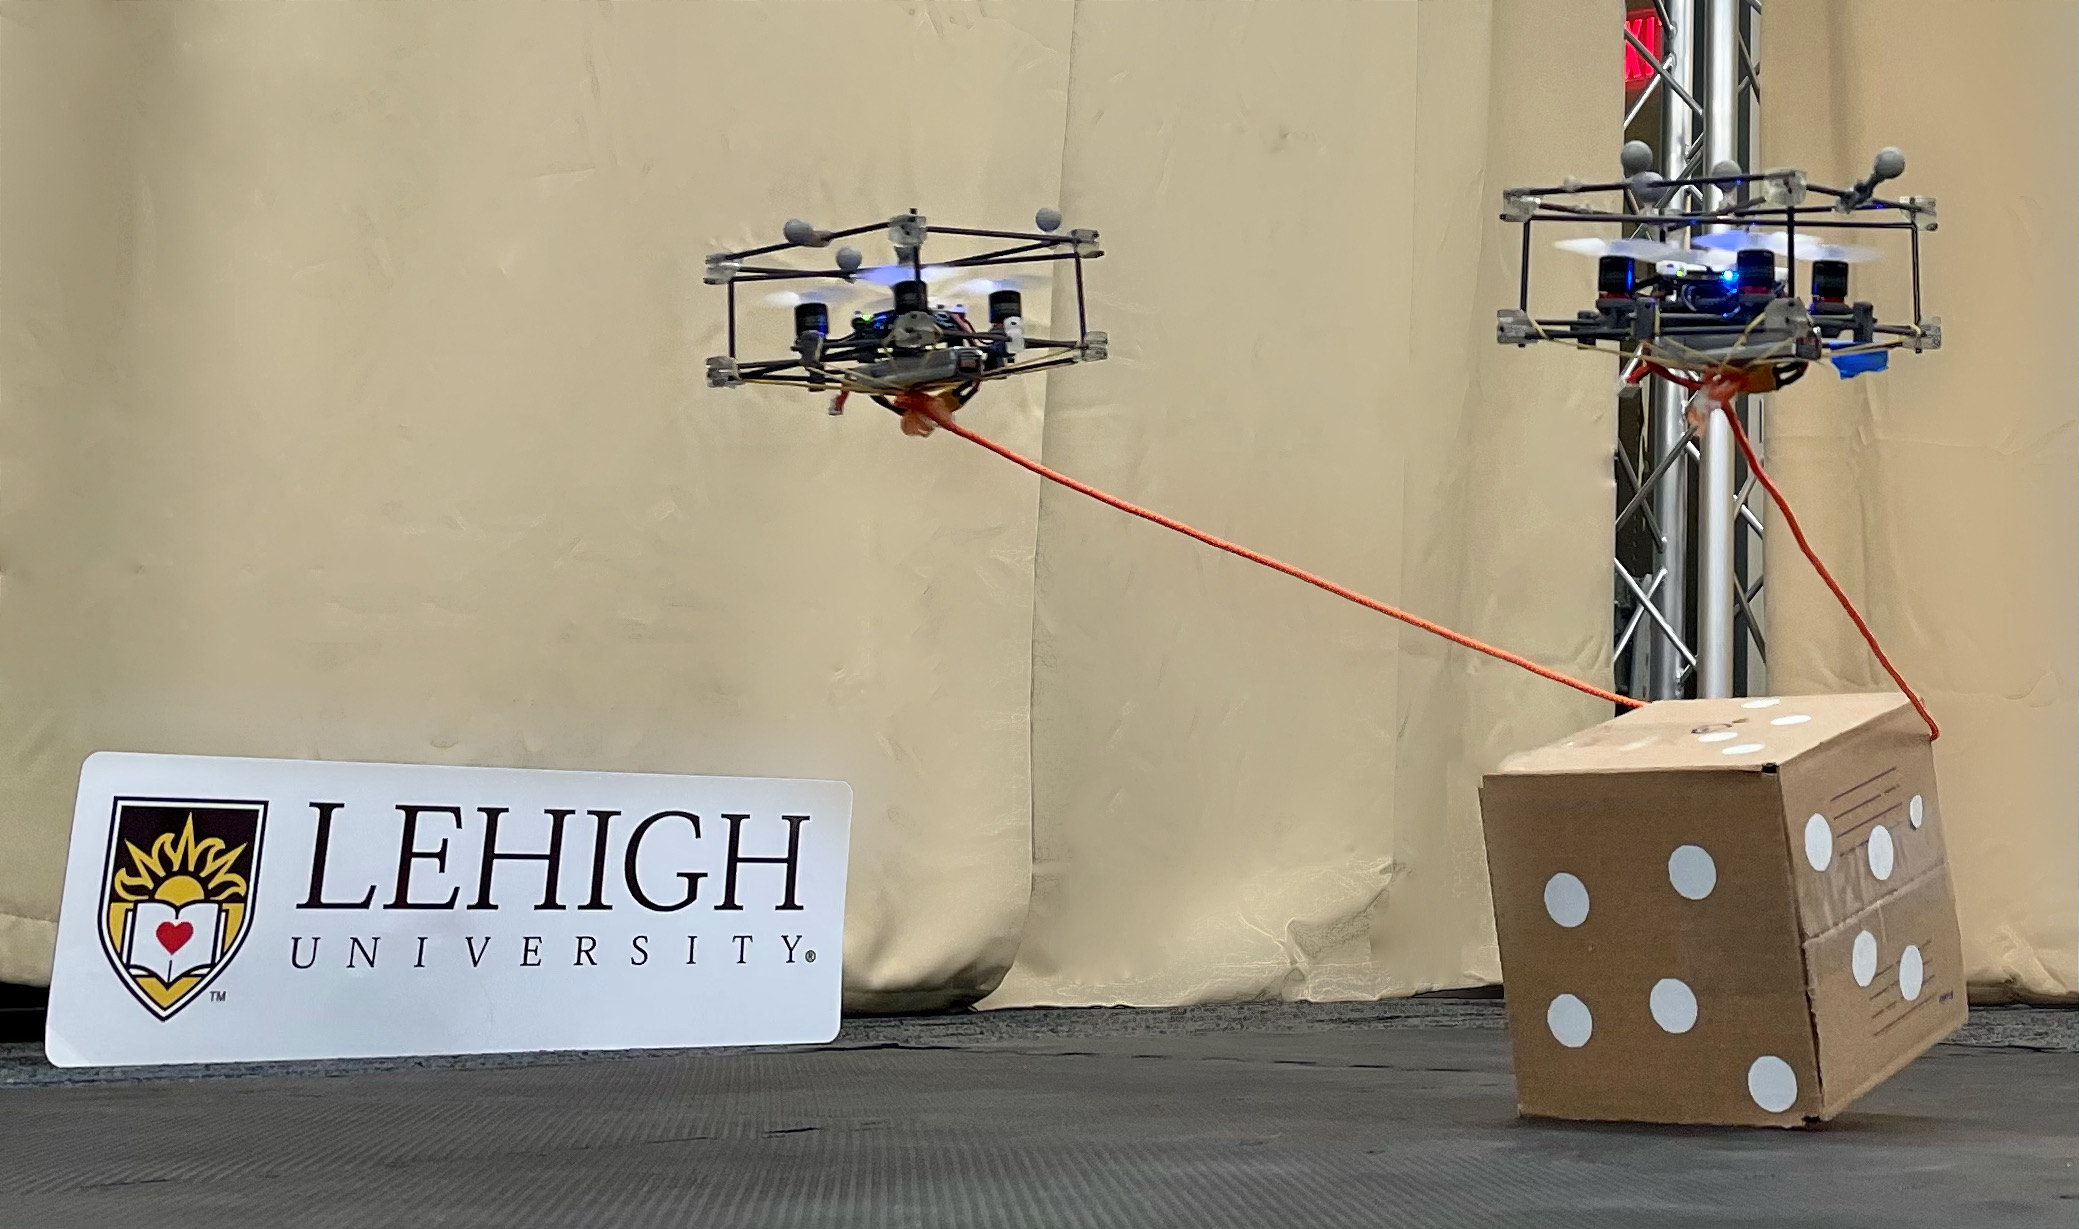
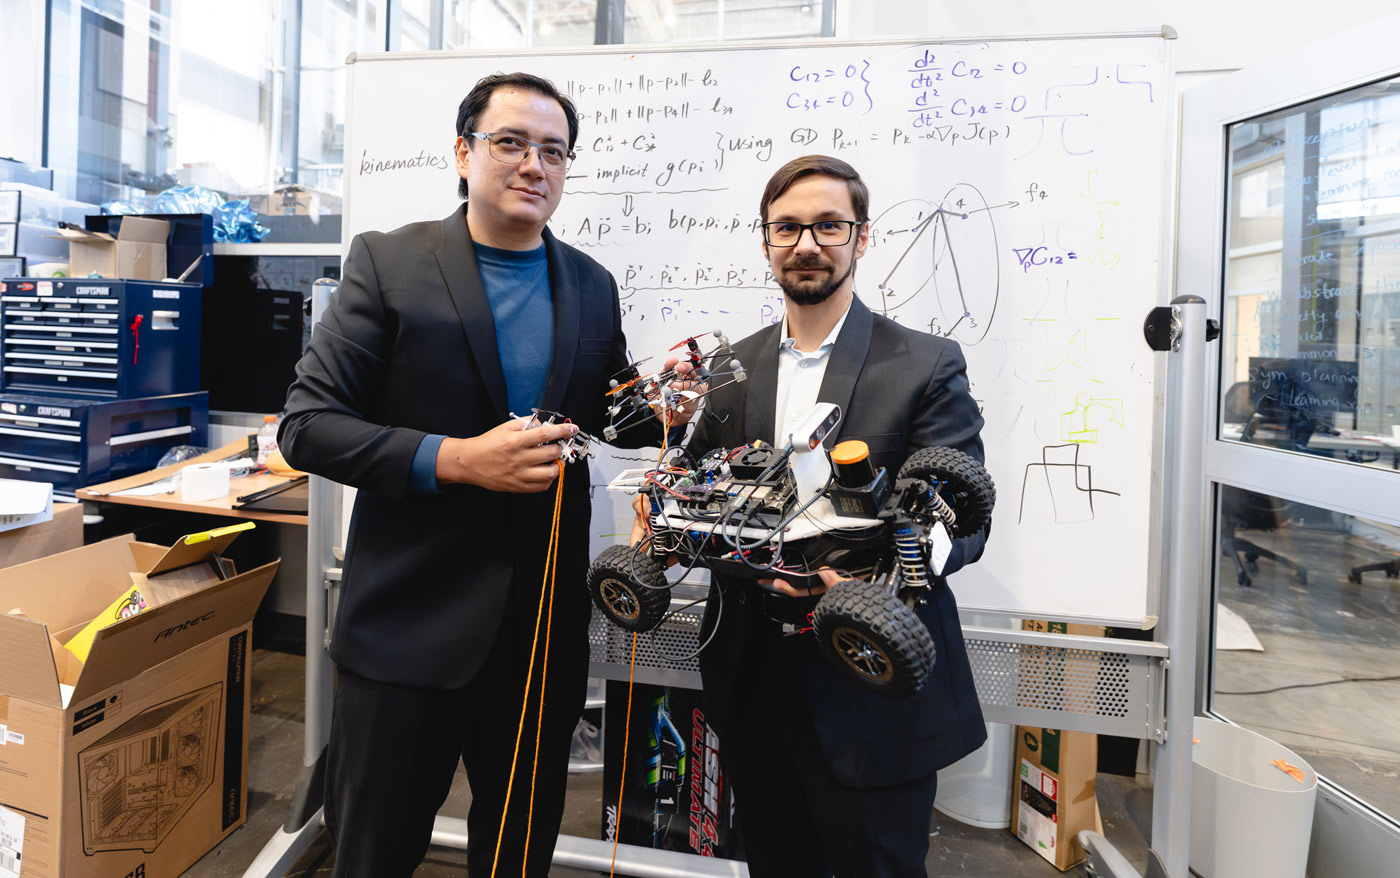
We develop cooperative aerial robots that assemble, manipulate, and work together. Exploring what becomes possible when robots act as a swarm.

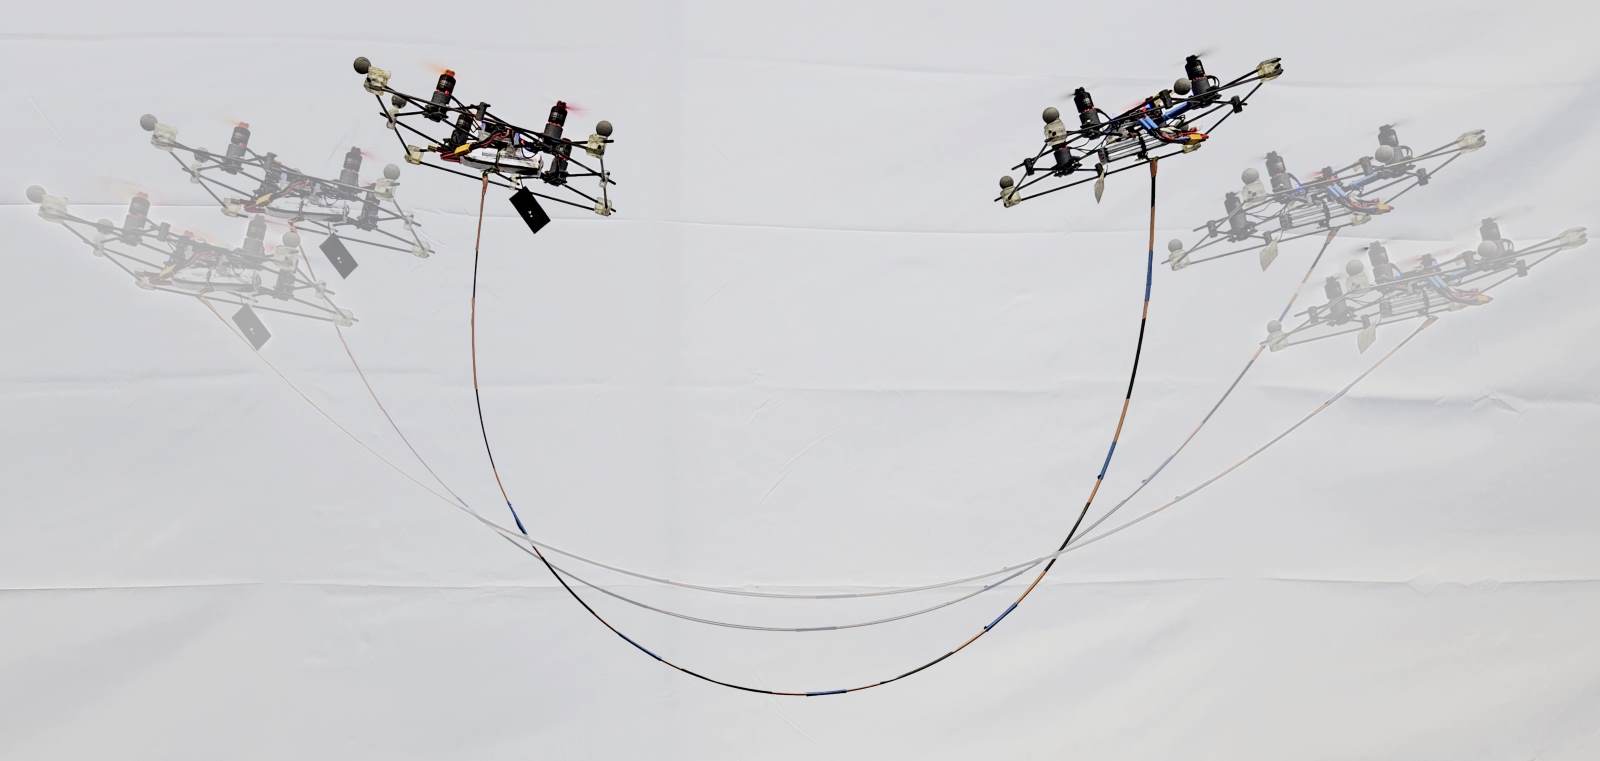
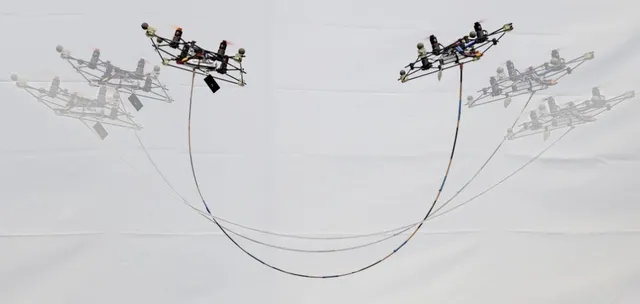
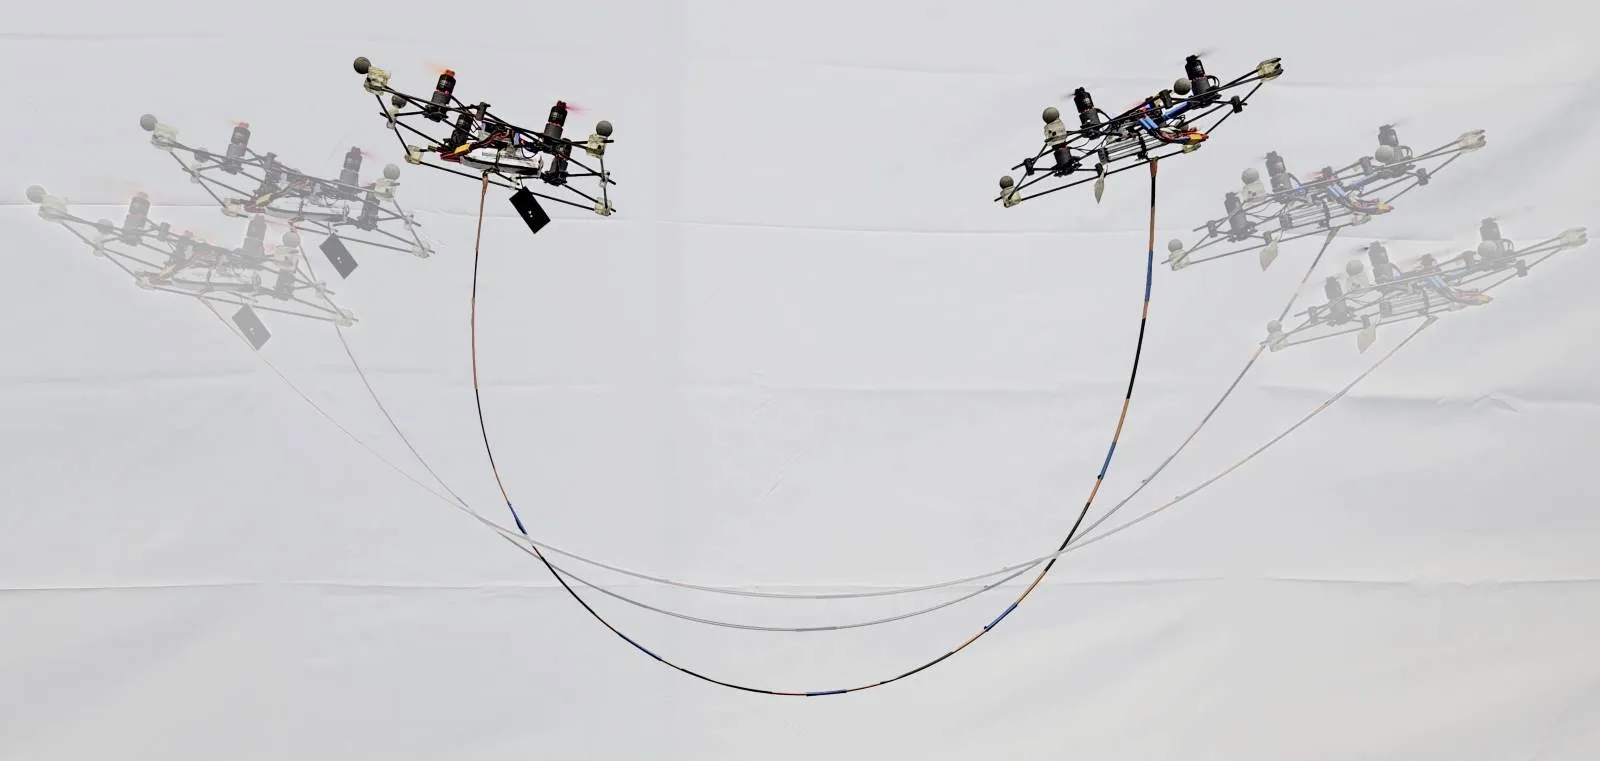
A pair of aerial robots cooperatively bending a flexible object in flight
Cooperative aerial manipulation · SwarmsLabOur NSF CAREER research

Robots working together

From individual robots to collective capability.

All research

Research in print

Recent publications

All publications →
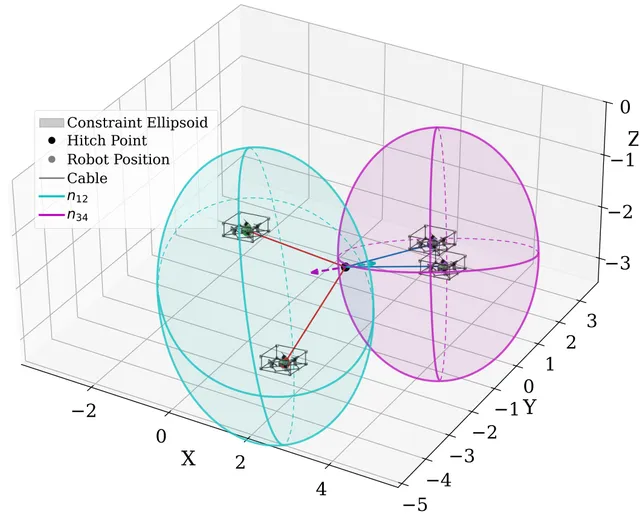
  1. Four aerial robots connected by interlacing cables, with ellipsoids illustrating the hitch constraints.
    2026Conference paper

    From Ellipsoids to Midair Control of Dynamic Hitches

    Jiawei Xu, Subhrajit Bhattacharya, David Saldaña

    2026 American Control Conference (ACC)

    BibTeX
    @inproceedings{xu2026ellipsoids,
      title={From Ellipsoids to Midair Control of Dynamic Hitches},
      author={Xu, Jiawei and Bhattacharya, Subhrajit and Saldaña, David},
      booktitle={2026 American Control Conference (ACC)},
      year={2026},
      url={https://arxiv.org/abs/2602.08116}
    }
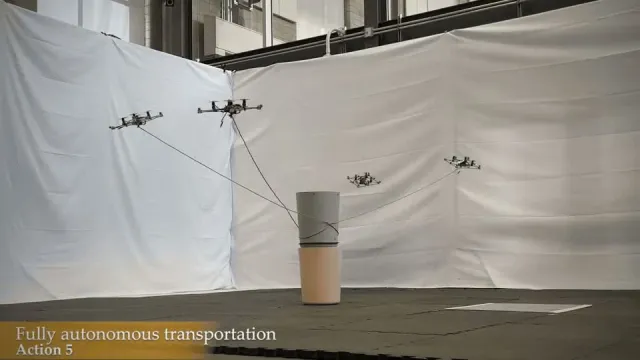
  2. Four quadrotors lifting a cylindrical object secured by interlaced cables.
    2026Journal article

    From Hitch to Lift: Autonomous Cable Interlacing by Multi-UAV Teams for Aerial Grasping and Transportation

    Diego S. D'Antonio, Tongshu Wu, Subhrajit Bhattacharya, David Saldaña

    IEEE Transactions on Robotics

    BibTeX
    @article{2026-from-hitch-to-lift-autonomous-cable-interlacing-by-multi-uav-teams-for-aerial-grasping-and-transportation,
      title = {From Hitch to Lift: Autonomous Cable Interlacing by Multi-UAV Teams for Aerial Grasping and Transportation},
      author = {Diego S. D'Antonio and Tongshu Wu and Subhrajit Bhattacharya and David Saldaña},
      year = {2026},
      journal = {IEEE Transactions on Robotics},
      doi = {10.1109/tro.2026.3677011}
    }
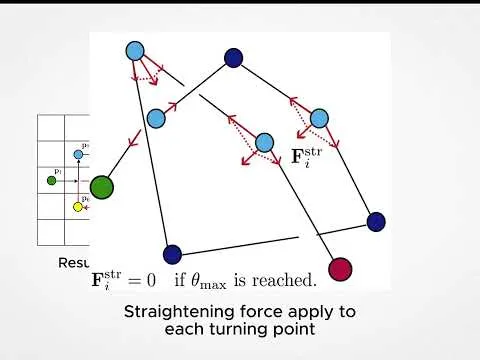
  3. Diagram from the knot-formation demonstration showing cable turning points and force directions.
    2026Conference paper

    Tying Knots in the Air: Reducing the Number of Quadrotors for Aerial Knot Formation

    Tongshu Wu, Edward Lopez, Diego S. D'Antonio, David Saldaña

    2026 IEEE International Conference on Robotics and Automation (ICRA)

    BibTeX
    @inproceedings{wu2026tying,
      title={Tying Knots in the Air: Reducing the Number of Quadrotors for Aerial Knot Formation},
      author={Wu, Tongshu and Lopez, Edward and D'Antonio, Diego S. and Saldaña, David},
      booktitle={2026 IEEE International Conference on Robotics and Automation (ICRA)},
      year={2026},
      pages={9871--9878},
      doi={10.1109/ICRA57385.2026.11697504}
    }
  4. Two quadrotors transporting and bending a flexible carbon-fiber strip.
    2025Journal article

    AirBender: Adaptive Transportation of Bendable Objects Using Dual UAVs

    Jiawei Xu, Longsen Gao, Rafael Fierro, David Saldaña

    IEEE Robotics and Automation Letters

    BibTeX
    @article{2025-airbender-adaptive-transportation-of-bendable-objects-using-dual-uavs,
      title = {AirBender: Adaptive Transportation of Bendable Objects Using Dual UAVs},
      author = {Jiawei Xu and Longsen Gao and Rafael Fierro and David Saldaña},
      year = {2025},
      journal = {IEEE Robotics and Automation Letters},
      pages = {2790-2797},
      volume = {10},
      number = {3},
      doi = {10.1109/lra.2025.3536276},
      url = {https://doi.org/10.1109/lra.2025.3536276}
    }
Lehigh Swarms students and mentors together at a robotics competition

Build. Fly. Collaborate.

A place to learn by doing.

The Lehigh Aerial Swarms Club brings students together to build autonomous robots, develop new skills, and take on the Defend the Republic competition.

Explore the club →