Brian Zhu
Undergraduate research assistant
Lead Flight Software Engineer at Argo Space
Brian is a Lead Flight Software Engineer at Argo Space.
At SwarmsLab, he was an undergraduate research assistant.
Selected publications
 2022Conference paper
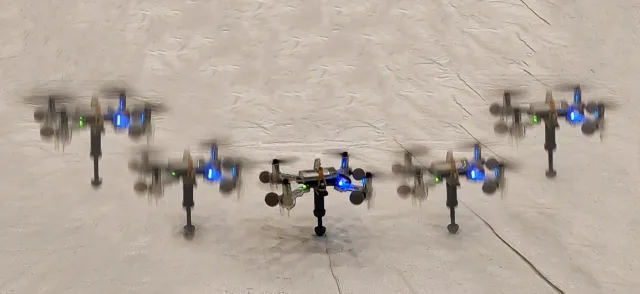
PogoDrone: Design, Model, and Control of a Jumping Quadrotor
Brian Zhu, Jiawei Xu, Andrew Charway, David Saldaña
2022 IEEE International Conference on Robotics and Automation
Abstract
We present a design, model, and control for a novel jumping-flying robot that is called PogoDrone. The robot is composed of a quadrotor with a passive mechanism for jumping. The robot can continuously jump in place or fly like a normal quadrotor. Jumping in place allows the robot to quickly move and operate very close to the ground. For instance, in agricultural applications, the jumping mechanism allows the robot to take samples of soil. We propose a hybrid controller that switches from attitude to position control to allow the robot to fall horizontally and recover to the original position. We compare the jumping mode with the hovering mode to analyze the energy consumption. In simulations, we evaluate the effect of different factors on energy consumption. In real experiments, we show that our robot can repeatedly impact the ground, jump, and fly in a physical environment.
BibTeX
@inproceedings{Zhu2022,

title = {PogoDrone: Design, Model, and Control of a Jumping Quadrotor},

author = {Brian Zhu and Jiawei Xu and Andrew Charway and David Saldaña},

url = {https://arxiv.org/pdf/2204.00207.pdf},

doi = {https://doi.org/10.48550/arXiv.2204.00207},

year  = {2022},

date = {2022-04-01},

urldate = {2022-04-01},

booktitle = {2022 IEEE International Conference on Robotics and Automation},

abstract = {We present a design, model, and control for a novel jumping-flying robot that is called PogoDrone. The robot is composed of a quadrotor with a passive mechanism for jumping. The robot can continuously jump in place or fly like a normal quadrotor. Jumping in place allows the robot to quickly move and operate very close to the ground. For instance, in agricultural applications, the jumping mechanism allows the robot to take samples of soil. We propose a hybrid controller that switches from attitude to position control to allow the robot to fall horizontally and recover to the original position. We compare the jumping mode with the hovering mode to analyze the energy consumption. In simulations, we evaluate the effect of different factors on energy consumption. In real experiments, we show that our robot can repeatedly impact the ground, jump, and fly in a physical environment.},

keywords = {aerial manipulation, aerial robot, quadrotor},

pubstate = {published},

tppubtype = {inproceedings}

}